
Product added to cart
HN3806 Photoelectric Rotary Encoder - 600 P/R, 2-Phase
$9.9500
In stock
SKU
SEN-23-007
Volume discounts:
- +25 4 % $9.5200
- +50 6 % $9.3100
- +100 9 % $9.0900
- +300 11 % $8.8800
- +500 13 % $8.6700
Ships in 2-3 business days, then:
Free delivery in 12-15 days by Tracked Economic Shipping on orders over $100.
Free delivery in 7-10 days by Express Shipping on orders over $300.
More shipping info
Shop with confidence Learn More
 FZ0535 Rotary Encoder Module Previous

HN3806 600 P/R Encoder Overview and Specifications
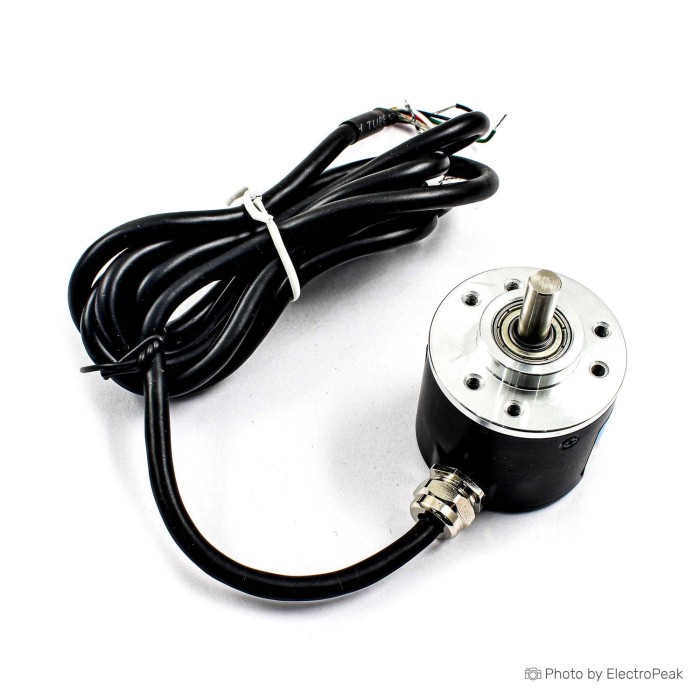
The HN3806 Photoelectric Rotary Encoder - 600 P/R, 2-Phase is an enclosed, shaft-mounted incremental optical encoder for tracking relative shaft position, direction, and rotational speed. Inside its 38 mm housing, a rotating grating disc and optocoupler generate two orthogonal square-wave pulse streams—phase A and phase B—as the 6 mm shaft turns. It suits automation rigs, test benches, and robotics projects where your controller can decode quadrature pulses and you can provide external pull-up resistors. This is not an absolute encoder, so it will not retain shaft position across a power cycle; installations requiring fully documented industrial environmental ratings or a verified manufacturer datasheet should use dedicated industrial components.
Shaft-mounted incremental units such as the HN3806 are fundamentally different from panel-mount human-machine interface controls. A panel control handles low-speed manual adjustments and often includes an integrated pushbutton. This unit is built for continuous mechanical rotation, coupled directly to motors, lead screws, or measurement wheels. Explore other sensing formats in the optical and incremental rotary encoders selection.
Specifications of HN3806 Photoelectric Rotary Encoder - 600 P/R, 2-Phase
- Model: HN3806-AB
- Pulse Number: 600
- Power Source: DC 5-24V
- Shaft Diameter: 6mm
- Outer Diameter: 38mm
- Output: AB 2phase output rectangular orthogonal pulse circuit
- Output Type: NPN open-collector
- Maximum Mechanical Speed: 5000 R / min
- Response Frequency: 30KHz
- Cable Length: 2 meter
- Wire Color - Green: A phase
- Wire Color - White: B phase
- Wire Color - Red: Vcc power +
- Wire Color - Black: V0
HN3806 600 P/R Encoder Signal, Speed, and Mechanical Fit
The HN3806 uses an orthogonal two-phase output for rotational feedback. Phase A and phase B produce square waves offset by 90 electrical degrees. By tracking which channel changes first, your controller can determine shaft direction, while pulse frequency indicates shaft velocity. As an incremental encoder with only A and B channels documented, it provides relative displacement rather than absolute angle. No index or Z channel is documented to provide a hardware zero reference once per turn.
Signal-processing bandwidth needs consideration when selecting a 600 P/R encoder. A pulse number of 600 produces substantially more transition edges than lower-resolution models. Quadrature decoding logic can evaluate signals in x1 mode, counting one edge of channel A; x2 mode, counting rising and falling edges of channel A; or x4 mode, counting both edges of both channels A and B. Depending on the software routine, one mechanical revolution can register 600, 1,200, or 2,400 counts. Calibrate firmware position calculations for the specific decoding method you implement.
Operating speed must also be balanced against signal-frequency limits. The published specifications list a Maximum Mechanical Speed of 5000 R / min and a Response Frequency of 30KHz. Running a 600 P/R encoder at 5,000 rpm generates 50,000 full cycles per second on each signal channel (600 pulses × 5,000 rpm / 60 seconds = 50 kHz). Since 50 kHz exceeds the listed 30 kHz electrical response limit, the two maximum figures cannot be used at the same time. At 30 kHz, maximum electrical throughput limits shaft speed to 3,000 rpm (30,000 × 60 / 600). For high rotational speeds, check your target rpm against controller interrupt handling and signal bandwidth.
Mechanical installation centers on the 6 mm solid shaft and 38 mm outer body diameter. The integrated 2-meter cable provides ample length for control-cabinet routing without inline splices. Precise shaft length, pilot flange dimensions, and face mounting-hole patterns are not documented. Measure the physical unit before machining rigid brackets or custom motor plates. For tight spaces or low-voltage motor shafts where a bare disc is preferable to an enclosed housing, the 100-line steel optical encoder disc provides an alternative 5 V optical arrangement with a lower pulse count.
HN3806 600 P/R Encoder Wiring, First Test, and Limitations
The HN3806 uses an NPN open-collector output topology. Its internal output transistors act as switches connected to ground (V0) and do not supply positive voltage themselves. Each signal wire needs an external pull-up resistor, typically between 1 kΩ and 100 kΩ, tied to the logic supply of your receiving microcontroller or counter circuit. Never connect signal wires directly to positive supply rails without a resistor: pulling an active open-collector transistor straight to VCC will short the output stage and destroy the internal switching triode.
Keep the encoder power supply separate from the logic reference. While the encoder accepts a DC 5–24V supply on its red wire, that input voltage does not set the signal voltage. If you power the encoder from a 24 V industrial supply, pull the green and white data lines up to 3.3 V or 5 V to match your microcontroller inputs. Microcontrollers with internal pull-ups, including the input-pull-up mode on an Arduino, can pull the lines high internally for bench testing. Lower-resistance external pull-ups, around 2.2 kΩ to 4.7 kΩ, improve edge transitions when driving through the full 2-meter cable.
Factory wire assignments identify green as A phase, white as B phase, red as positive supply, and black as negative ground (V0). Documentation across related production batches occasionally transposes the signal wire colors, so verify your delivered unit before finalizing enclosure wiring. For temporary breadboard setups, a Breadboard Jumper Wire Kit - 140 Pieces makes it easier to place pull-up resistors and establish common-ground connections with your development board.
Follow this direct testing procedure to commission the encoder safely:
- Inspect the delivered unit to verify the wire count, cable exit condition, and shaft rotation.
- Connect the red wire to a DC power source between 5 V and 24 V, and connect the black wire to the power supply ground.
- Connect the ground of your receiving controller directly to the encoder ground wire to ensure a shared reference.
- Install individual pull-up resistors between the green wire and your controller logic rail, and between the white wire and your controller logic rail.
- Connect the green and white wires to interrupt-capable digital input pins on your controller.
- Rotate the shaft slowly by hand while monitoring pin logic states to verify that both channels alternate between high and low.
- Confirm that clockwise rotation increments your software counter and counter-clockwise rotation decrements it; swap the A and B pin assignments in software if direction is inverted.
- Spin the shaft at your intended operating velocity to ensure your software loop or hardware timer registers pulses without dropping counts.
For code structures, input configuration, and interrupt routines, refer to this practical guide covering Arduino input-pull-up and quadrature-reading example implementations. Documentation for this encoder family is sparse. Exact internal schematic details and formal qualification records are not published, making initial bench validation necessary.
HN3806 600 P/R Encoder Applications and Position Feedback Uses
In maker and engineering projects, the HN3806-AB model has appeared in Arduino-based quadrature measurement experiments and ESP8266 software-defined radio rotary interface setups. This is limited project evidence. Its 600 pulse-per-revolution grating provides fine angular feedback for closed-loop motion control, laboratory dynamometers, and test fixtures.
Linear distance tracking is another category-level use. Fitted with an external measuring wheel of known circumference, the encoder can calculate web material feed, conveyor belt travel, or sheet-cutting lengths. Accurate measurement depends on mechanical stability: wheel slippage, runout, or surface compliance will introduce errors that software cannot correct. In CNC and robotics axes, the encoder can provide secondary shaft-position feedback when coupled to lead screws, provided your controller implements a startup homing sequence with mechanical limit switches to establish a datum point.
For projects involving rotational-velocity tracking or a custom tachometer, see the tutorial covering Arduino speed-sensor wiring and code example techniques. Installations that cannot perform a homing routine after power loss and require true angular awareness are better suited to an absolute sensor such as the AS5600 12-bit magnetic angle sensor than to an incremental optical unit.
HN3806 600 P/R Encoder vs Motor and Panel Encoder Alternatives
Encoder selection depends heavily on mechanical mounting, target resolution, and operating environment. The HN3806 provides a self-contained 38 mm body with internal bearings and a 6 mm shaft, making it suitable for belt drives, pulleys, or shaft-to-shaft coupling. Other encoder styles use different mechanical architectures:
| Encoder Type | Form Factor | Resolution / Output | Key Integration Distinction |
|---|---|---|---|
| HN3806 600 P/R | Enclosed 38 mm housing, 6 mm shaft | 600 P/R, NPN open-collector A/B | Independent shaft mounting; requires external pull-ups and 6 mm coupling. |
| Slotted Disc Optical | Bare 22 mm steel disc, external optocoupler | 100 lines, 5 V push-pull quadrature | Requires precise mechanical alignment between disc and slotted sensor. |
| Motor-Tail Magnetic | PCB ring mounted on rear motor shaft | 12 to 16 CPR, Hall-effect pulses | Directly fits specific DC gearmotors; low resolution, compact footprint. |
| Panel-Mount Mechanical | Compact bushing with detents, 6 mm shaft | ~20 PPR, mechanical contact switch | Designed for low-speed human input and menu selection; includes push switch. |
For specific DC gearmotors, the Hall-effect DC motor encoder mounts directly to the rear shaft of JGB37 and JGA25 motor frames, eliminating external brackets and flexible couplings. For user-interface design rather than motion tracking, the KY-040 mechanical encoder module and panel-mount EC11 rotary encoder switch provide tactile detents and built-in pushbuttons at low cost. Their mechanical brush contacts will wear out quickly under motor speeds.
The HN3806 series is also produced in alternative pulse counts, including 100, 200, 360, and 400 P/R versions. Match the pulse count to your controller's processing speed: lower pulse counts produce fewer interrupt events per second at high rpm, easing processor load when fine positional granularity is not required.
HN3806 600 P/R Encoder Accessories, Coupling, and Mounting Needs
Operating the HN3806 requires several mechanical and electrical accessories that are not included with the bare encoder.
Required Items
- DC Power Supply: A stable 5 V to 24 V DC source capable of supplying power through the red and black leads.
- Pull-Up Resistors: Two independent resistors (1 kΩ to 100 kΩ, with 2.2 kΩ to 10 kΩ typical) to pull channels A and B up to the controller logic level.
- Quadrature-Capable Receiver: A microcontroller, high-speed PLC counter module, or hardware decoder configured to process dual-channel orthogonal signals.
- Shaft Coupling: A flexible or rigid coupler with one bore sized exactly to 6 mm to connect the encoder shaft to your driving mechanism.
- Mounting Bracket: A custom plate or fixture designed to secure the 38 mm encoder face and prevent housing rotation during operation.
Recommended Items
- Prototyping Jumper Wires: Use a Breadboard Jumper Wire Kit - 140 Pieces to organize pull-up connections and signal lines on a test bench.
- Flexible Coupler (6 mm Bore): Use a zero-backlash flexible beam or spider coupling matched to 6 mm. Standard 5x5 mm or 5x8 mm 3D printer couplings do not match this 6 mm shaft diameter.
- Oscilloscope or Logic Analyzer: A bench instrument helps confirm signal phase shift, verify edge rise times, and troubleshoot suspected wiring reversals.
Optional Items
- Optocouplers or Line Drivers: Recommended for electrically noisy environments or when transmitting pulses over long distances to 24 V PLC cabinets.
- Shielded Cable Wrap or Conduit: External braided shielding improves noise immunity in environments with high EMI from motor drives and inverters.
HN3806 600 P/R Encoder FAQ
Do I need pull-up resistors for the HN3806 600 P/R encoder?
Yes. Pull-up resistors are required because the encoder uses NPN open-collector outputs. The internal transistors switch signals to ground but cannot drive them high themselves. Connect one pull-up resistor between phase A and your logic voltage, and a second pull-up resistor between phase B and your logic voltage. Never connect the signal wires directly to positive power without a resistor, as this will damage the output transistors.
Can I use this HN3806 encoder with Arduino, ESP8266, Raspberry Pi, or a PLC?
Yes, provided the inputs can accept quadrature signals and use a safe voltage reference. Connect encoder ground to controller ground, pull the A and B lines up to the controller's logic voltage (3.3 V for ESP8266 and Raspberry Pi; 5 V for standard Arduino boards), and use hardware timers or interrupt pins. For a PLC, confirm that the input cards support open-collector sinking inputs and include a high-speed counter rated for your expected pulse frequency.
Can I power the encoder from 24 V and connect A/B directly to 3.3 V or 5 V GPIO?
You can power the encoder from 24 V while reading it with low-voltage GPIO, but only if the pull-up resistors connect to 3.3 V or 5 V. The open-collector transistors simply pull down the voltage applied through the resistors. Connecting the pull-up resistors to the 24 V supply rail will feed 24 V into your microcontroller pins and destroy them.
Which HN3806 wire is A phase and which is B phase?
The standard wiring list identifies green as phase A and white as phase B. Red is positive power, and black is ground. Factory color coding can occasionally vary between production lots, so verify rotation on your workbench before securing final connections. If your software reports movement in the wrong direction, swapping the green and white inputs will reverse the counted direction.
How many counts per revolution does a 600 P/R encoder provide in software?
The encoder hardware produces 600 complete electrical cycles per revolution on each channel. Software counts depend on the decoding mode: x1 decoding yields 600 counts per turn, x2 decoding yields 1,200 counts per turn, and x4 decoding yields 2,400 counts per turn. Calibrate firmware scaling to match your selected quadrature decoding routine.
Can the HN3806 600 P/R encoder run at 5,000 rpm?
The physical bearings are rated for a Maximum Mechanical Speed of 5000 R / min, but the electrical output stage is limited by a 30KHz Response Frequency. At 600 P/R, operation at 5,000 rpm generates a 50 kHz signal, exceeding the 30 kHz electrical rating and causing missed pulses. To remain within the 30 kHz electrical limit, keep rotational speed below 3,000 rpm.
Does this encoder provide an index pulse or absolute position after power loss?
No. This encoder provides only two-phase incremental A and B outputs. No index or Z channel is documented to signal a single zero pulse per turn, and it does not store angular position when power is removed. Systems requiring an absolute position reference must perform a homing routine using an external limit switch or optical flag after startup.
Is a shaft coupler or mounting bracket included?
Hardware inclusions are not documented, so plan to source your own coupling and mounting hardware. You will need a flexible coupling sized for a 6 mm shaft on the encoder side and a mounting plate suited to the 38 mm outer body diameter. For initial bench testing, a Breadboard Jumper Wire Kit - 140 Pieces provides convenient connections. If you need a manual panel dial rather than a machine-mounted shaft encoder, consider the KY-040 mechanical encoder module, or browse other rotary encoder types for position sensing and user interfaces.
Purchase Decision Summary
| Evaluation | Application Fit |
|---|---|
| Ideal for | Robotics, test stands, and automation mechanisms needing relative position, speed, or direction feedback from a 6 mm rotating shaft where a home routine is acceptable. |
| Maybe for | Arduino, ESP8266, and PLC installations where the user can design a custom 38 mm mounting bracket, wire external pull-ups, and keep pulse frequencies below 30 kHz. |
| Consider another option if | You require absolute position memory after power loss, an index (Z) pulse, panel-mount menu navigation, documented industrial certifications, or continuous speeds above 3,000 rpm at 600 P/R. |
Buying Checklist
- Verify that your project requires relative incremental feedback rather than absolute angle tracking.
- Confirm that an external homing switch or routine can be implemented if your machine requires a startup datum.
- Ensure your mechanism can accommodate a 6 mm diameter solid encoder shaft.
- Check that the 38 mm outer housing diameter fits your mechanical enclosure clearances.
- Plan to measure the shaft length and face-mounting hole pattern on the delivered unit before fabricating rigid brackets.
- Confirm your microcontroller or PLC can process quadrature pulse rates up to your target speed without dropping counts.
- Verify that your operating shaft speed stays below 3,000 rpm to remain within the 30 kHz electrical response limit.
- Prepare two pull-up resistors (1 kΩ to 100 kΩ) tied to a logic rail safe for your microcontroller GPIO.
- Establish a shared common ground between the encoder power supply and your receiving controller.
- Plan to verify the A and B wire colors on your delivered unit using a slow manual bench test.
| Interface Type | Digital |
|---|---|
| Operating Voltage (V) | 5-24V DC |
| Dimensions (mm) | 38 mm x 55 mm |
| Output Type | Digital |
| Resolution | 600 P/R |
| Number of Axes | 1-axis |
| Sampling Rate (Hz) | 30 kHz |
| Push Button | No |
| Sensor Type | Optical Rotary Encoder |
| Measurement Principle | Optical |
| Shaft Diameter (mm) | 6 mm |
Write Your Own Review

Please complete your information below to login.
Sign In
Create New Account